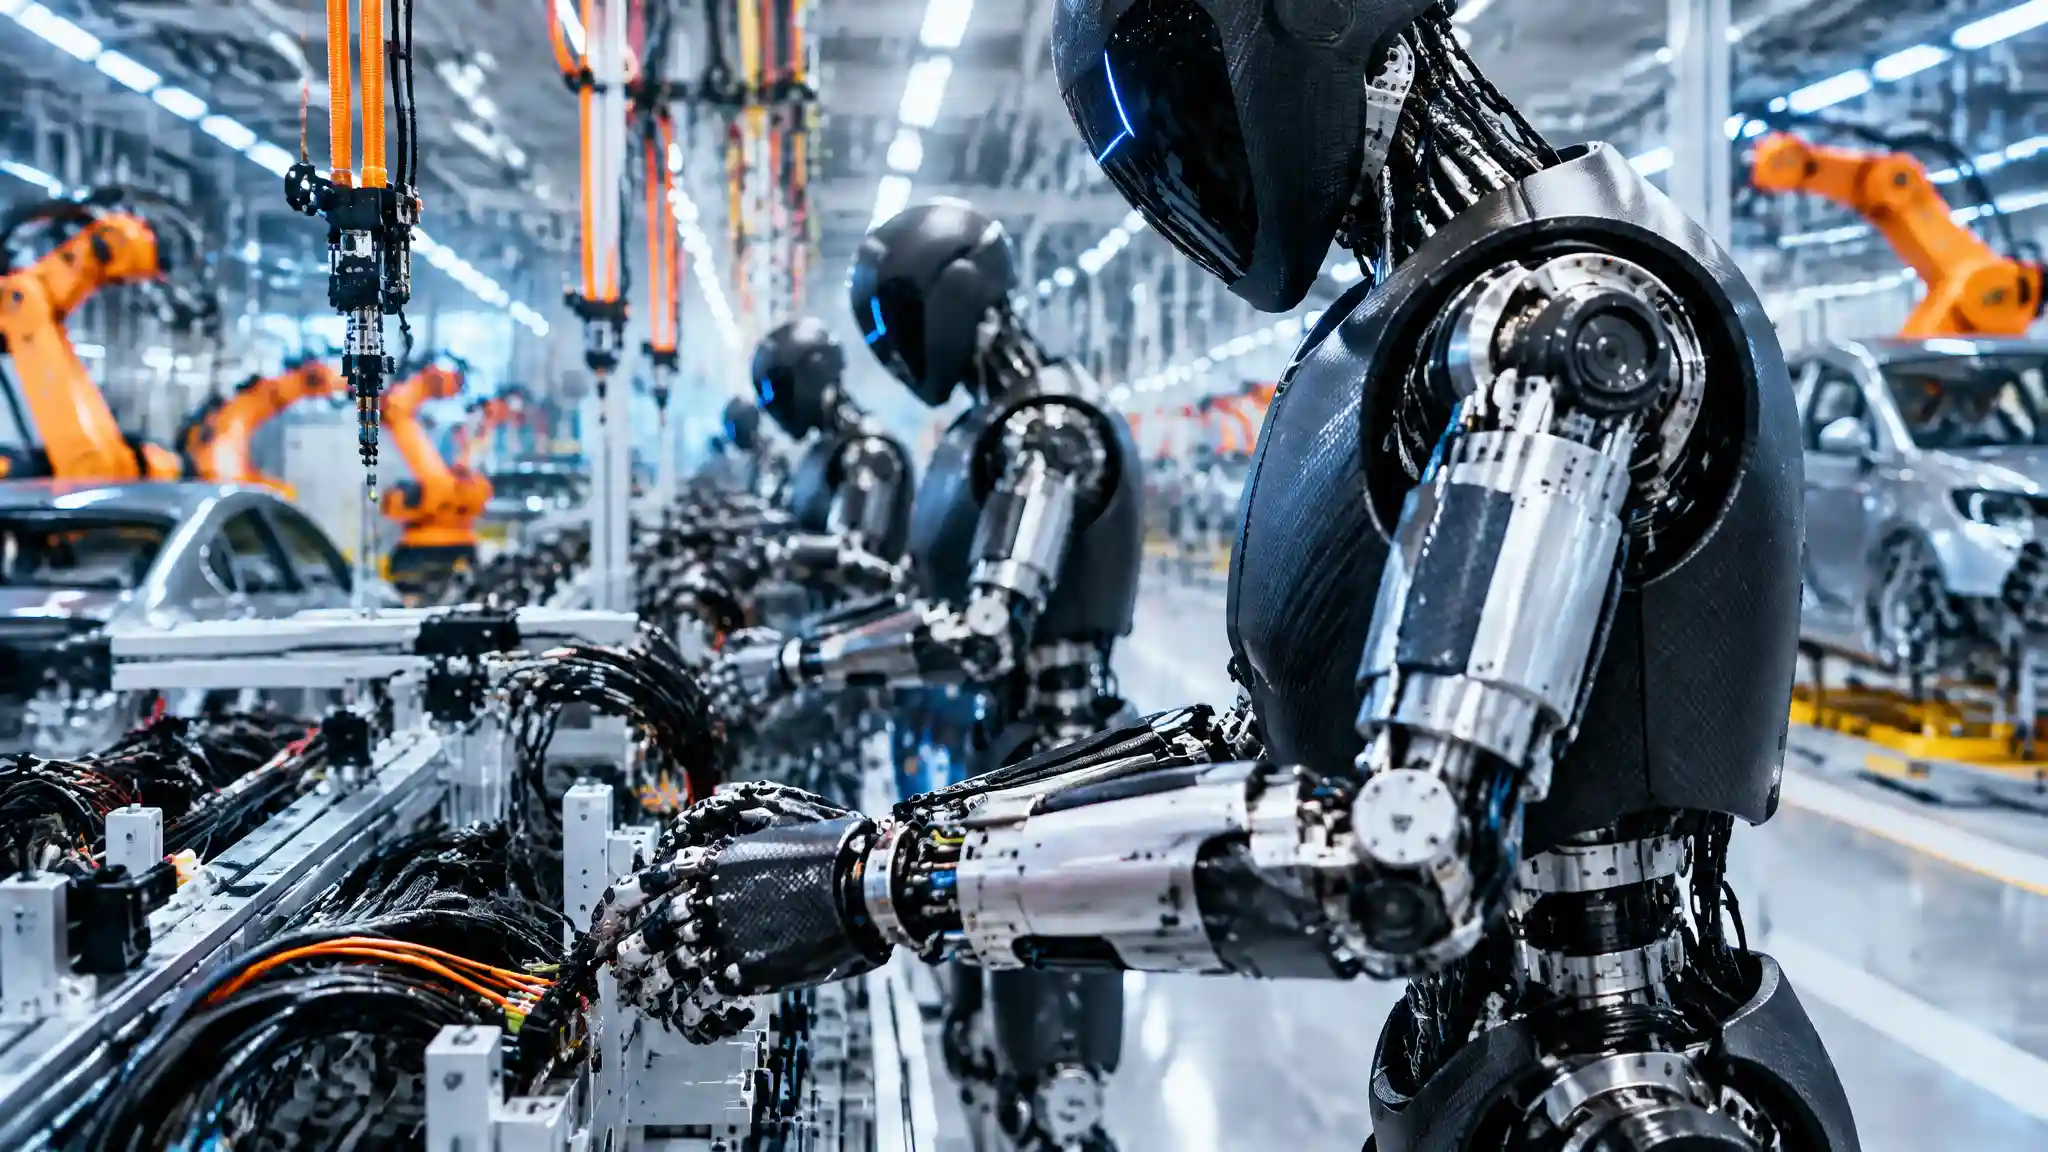
A humanoid's energy profile is set by its actuators. Clusters of high-torque electric joints on 48 V to 100 V buses drive hips, knees, shoulders and hands. Unlike a floor-bolted arm, a bipedal robot must spend energy just to stay upright: leg and torso motors hold torque against gravity, and that load turns into copper (I²R) heat even while the robot stands still. Assuming an average draw of 300 to 500 W across a working cycle, a robot on a 20-hour, multi-shift automotive schedule uses roughly 6.6 to 11 kWh per day once about 10% charging loss is included. That works out to about 2 to 3.3 MWh a year.
| Metric | Standard industrial robotic arm | High-mobility autonomous humanoid |
|---|---|---|
| Power supply | Hard-wired mains via controller cabinet | Onboard pack, roughly 2–2.5 kWh class |
| Continuous draw in cycle | ~0.2 kW (cobot) to several kW (heavy payload) | ~300–500 W (indicative) |
| Idle holding load | Near zero at the joints; brakes engage | Continuous balance and posture torque |
| Actuator thermal losses | Concentrated in duty-cycle peaks | Persistent I²R heat in load-bearing joints |
| Charging infrastructure | None | Docking or inductive charging bays, plus pack-testing and formation load |
| Fleet scaling | Replaces fixed tooling | Net-new load per unit deployed |
Pilots are already moving from demonstration to production. At BMW Group Plant Spartanburg, Figure 03 now picks unsorted parts into sequencing trolleys for just-in-sequence delivery, with wireless charging built into the platform. That follows a Figure 02 pilot in the body shop that supported more than 30,000 BMW X3 builds. At Plant Leipzig, BMW is piloting Hexagon's wheel-legged AEON humanoid in production areas including battery manufacturing for energy modules.
Scale changes the picture. A 1,000-robot plant adds roughly 0.3 to 0.5 MW of continuous demand. Ten million units in service would consume an estimated 20 to 33 TWh a year, about a tenth of the UK's annual electricity demand, before counting the energy used to build the robots and test their cells. For energy managers and investors, grid connection capacity, on-site generation and charge scheduling are becoming as decisive as actuator torque density.