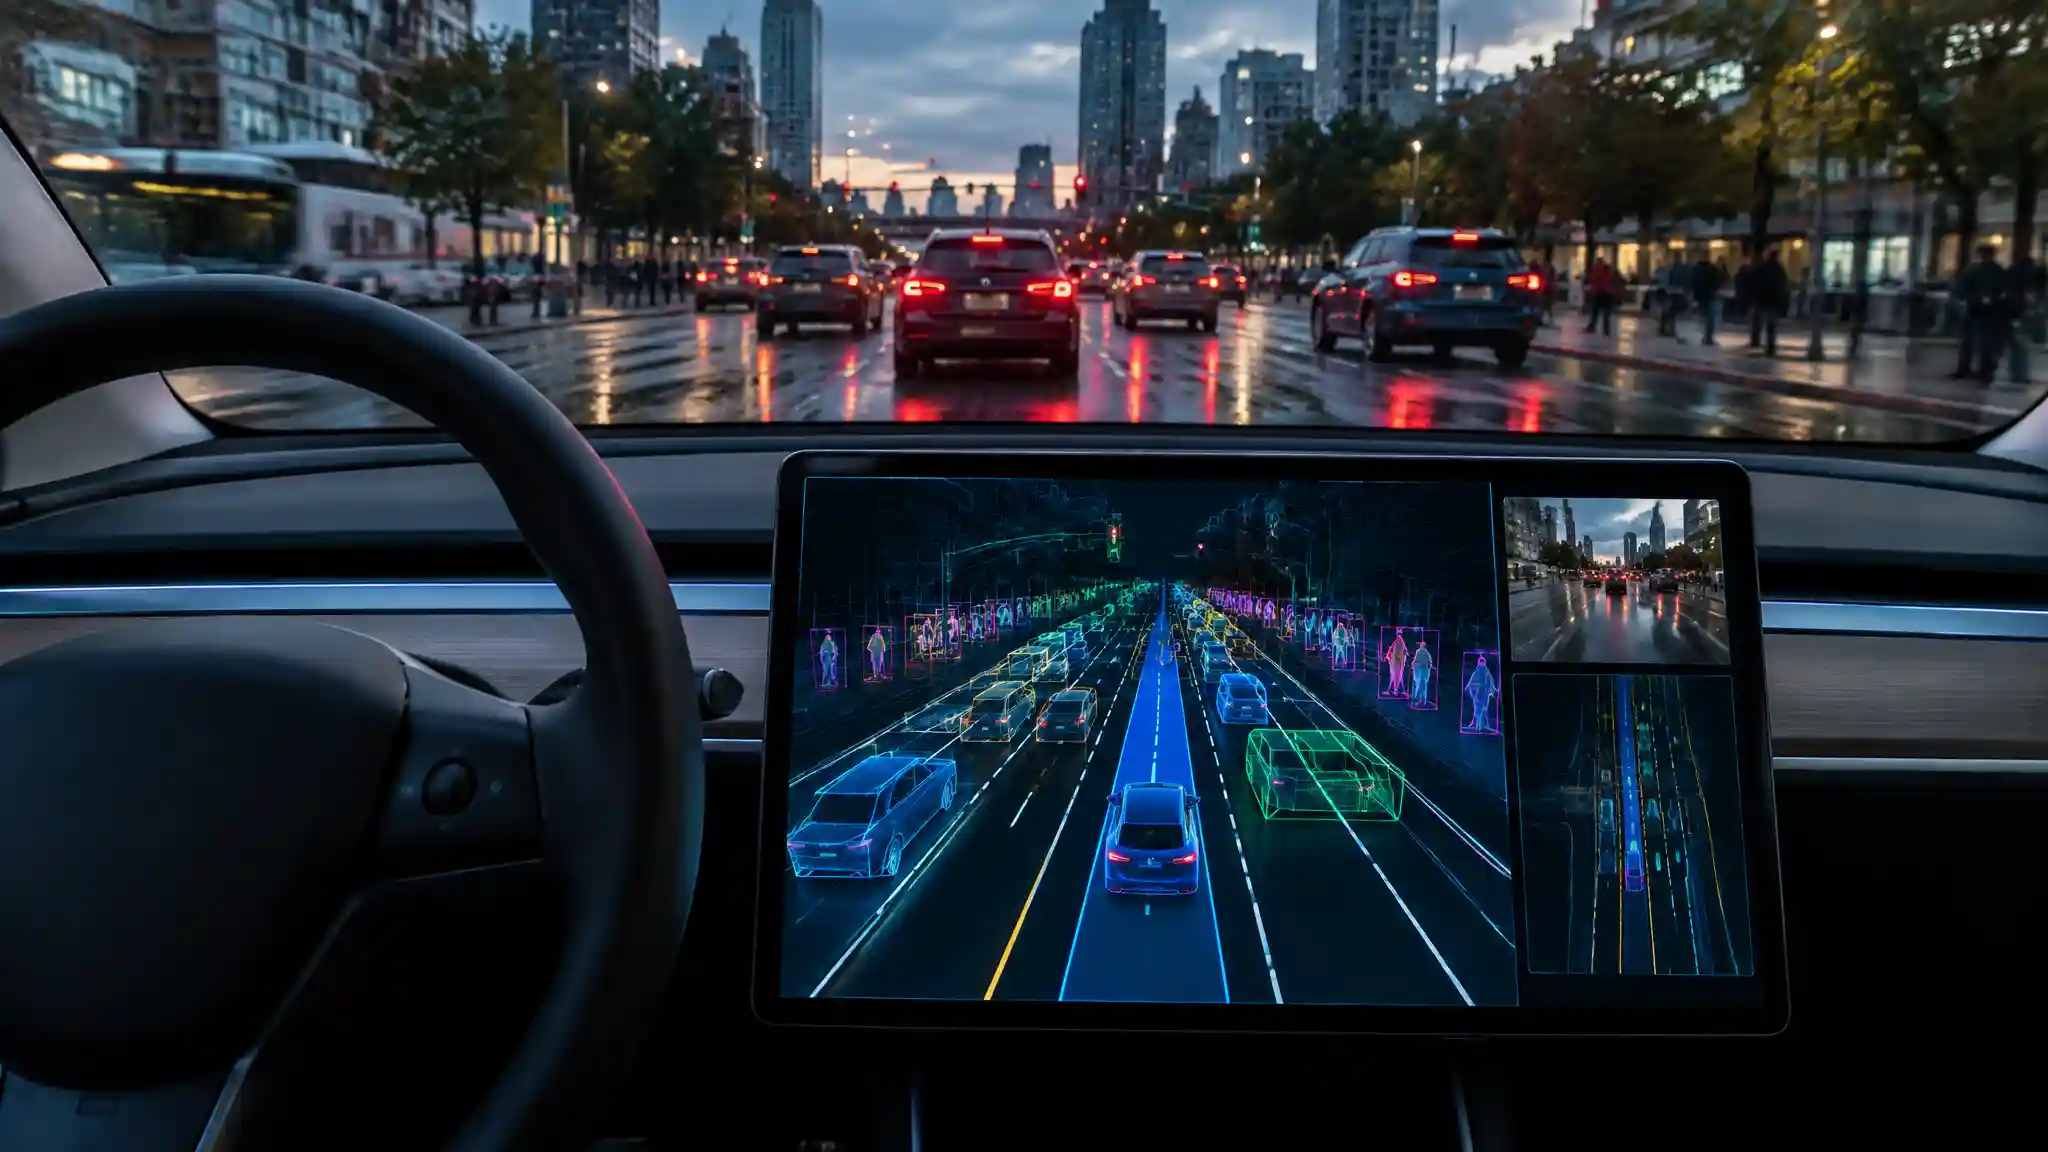
Tesla's current software replaces hand-written driving rules with a single end-to-end neural network. Raw camera video enters the model, and steering, acceleration and braking commands emerge together, with no separate perception or planning modules to tune independently. Once a model is frozen for release, its behaviour reflects its training data. Policies optimised for wide North American lane geometry do not translate naturally to complex European roundabouts, so extensive localised re-training is unavoidable. This is why identical software versions can behave very differently across jurisdictions: the architecture is shared, but the learned behaviour is not.
Regulation compounds the engineering gap. Tesla has moved from Full Self-Driving branding to Tesla Assisted Driving (TAD) in European markets, reflecting the supervised character of the system under UN R79 and R171. Type-approval granted by the Dutch RDW under Article 39 does not automatically apply in Great Britain. The Vehicle Certification Agency and the Department for Transport operate an independent compliance queue, and right-hand-drive behaviour must be validated separately.
China and Australia illustrate the remaining forks. China's stringent data localisation rules restrict how fleet footage can be moved, so an overseas, vision-only system struggles to harvest the native-road data that allows Huawei and XPeng to iterate faster. Australia, by contrast, has become the principal right-hand-drive proving ground, running advanced v14 builds on Hardware 4 and generating the left-side-driving data that a UK launch will depend on.
| Market | Active product name | Core regulatory pathway | Geographic constraints | Hardware chip requirements | Localised deployment target |
|---|---|---|---|---|---|
| United States | Full Self-Driving (Supervised) | Manufacturer self-certification | Few; state-level rules and driver supervision apply | Hardware 4 for latest builds | Broad public-road availability |
| European Union | Tesla Assisted Driving (TAD) | UNECE type-approval via the Dutch RDW (Article 39) | Provisional validation in select territories only | Hardware 4 | Staged roll-out following validation |
| United Kingdom | Not yet released; TAD branding expected | Independent VCA and DfT assessment under UN R79 and R171 | RDW approval not transferable; right-hand-drive validation required | Hardware 4 | Early 2027 at the earliest |
| China | Localised assisted-driving package | National approval plus data localisation compliance | Strict limits on moving fleet data across borders | Hardware 4 with locally trained models | Dependent on native-road training data |
| Australia | Full Self-Driving (Supervised) | National vehicle standards with supervised operation | Right-hand drive; supervision required | Hardware 4 running v14 builds | Primary right-hand-drive proving ground |
For regulatory specifiers and investors, the divergence is structural rather than temporary. Each market demands its own approval, its own training data and, in places, its own branding. Until UK assessment completes, currently expected no earlier than early 2027, rollout timelines should be treated as provisional, and any revenue model assuming simultaneous global release should be stress-tested accordingly. Developers should treat per-market validation cycles as a permanent cost of doing business.